Tactile sensing for robot hands

Robots can see.Now they can feel.

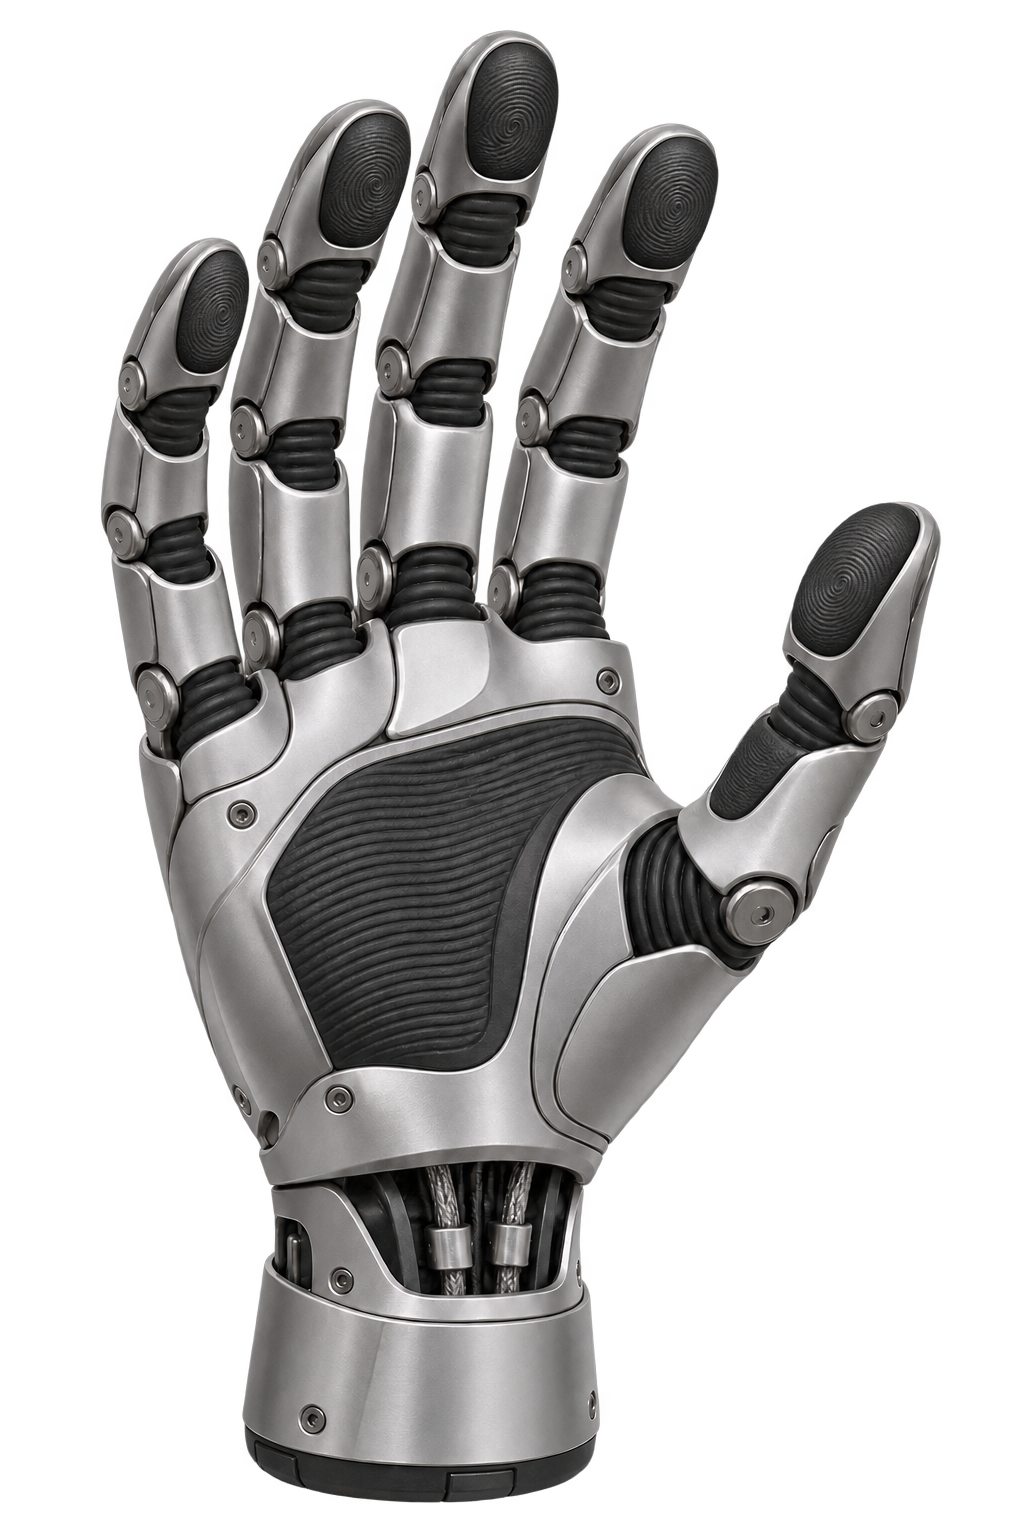
Dermis is building tactile skins that help robotic hands and grippers feel where they make contact, how much force they apply, and when an object starts to slip.

Silver robotic hand with black fingerprint-textured Dermis tactile pads
Concept render

Why touch

Vision tells a robot where an object is. Touch tells it where contact happens, how firmly it is holding, and when the object starts to shift.

The skin

Touch begins
at the surface.

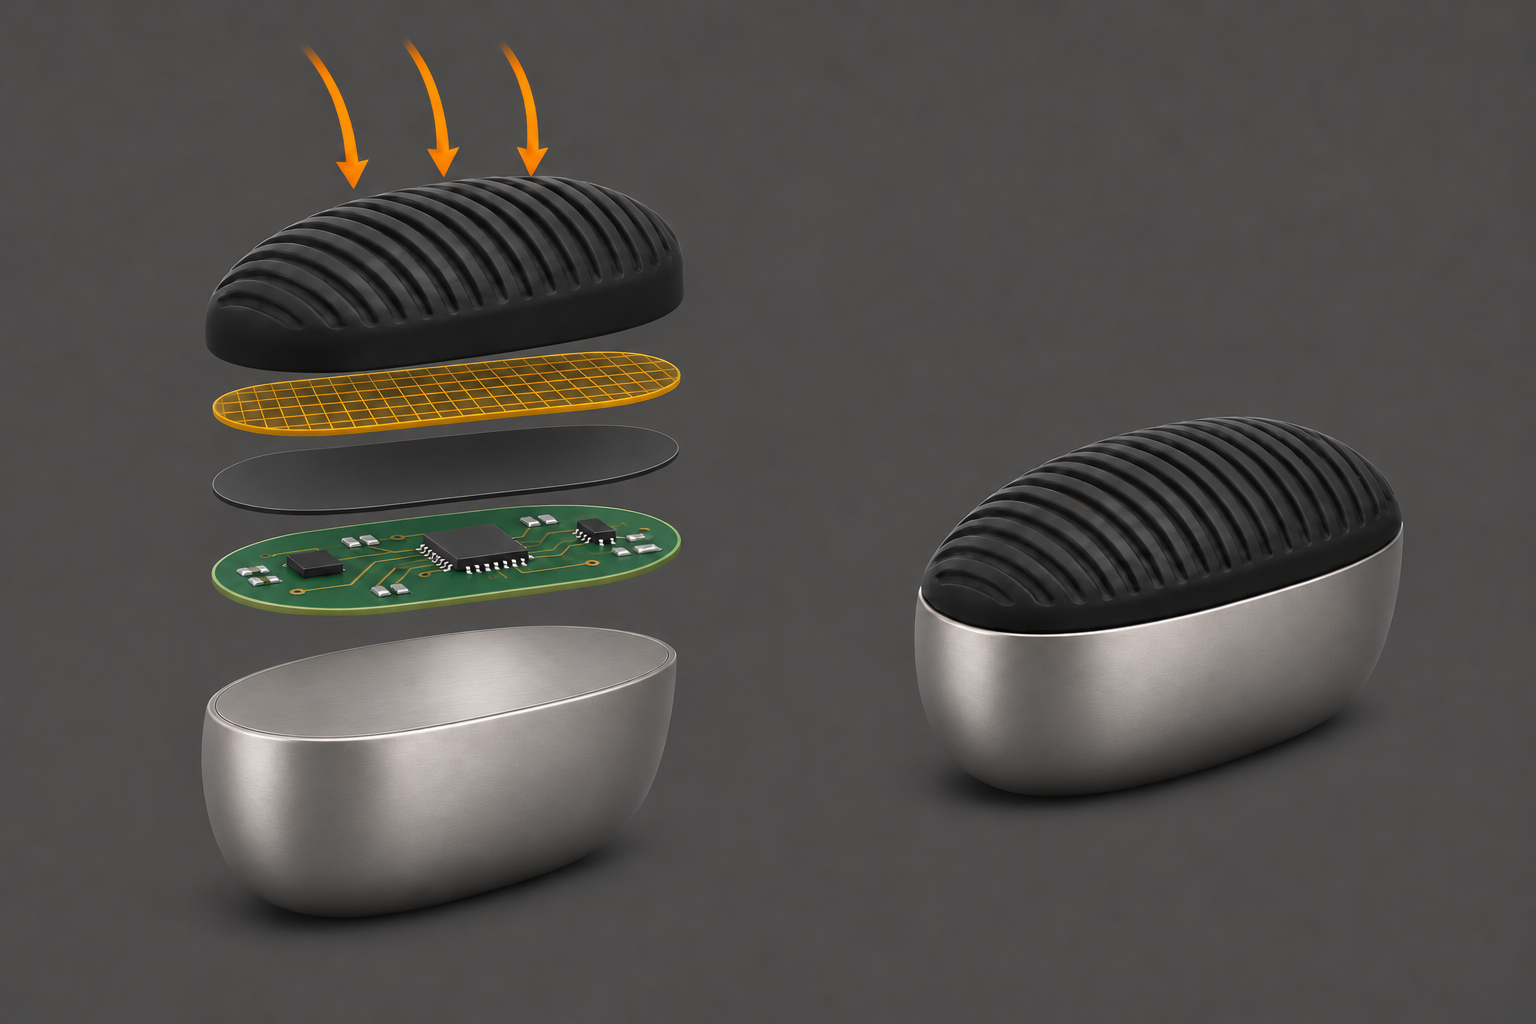
Exploded fingertip concept with orange force arrows, a ribbed contact pad, a yellow grid layer, a dark piezoresistive film, and one generic printed circuit board above a sealed housing. The assembled fingertip is on the right.

Signals Dermis is developing

  • Force
  • Shear
  • Grip
  • Slip
  • Temperature
  • Contact location

Fingertip concept

Applied force
Orange arrows show the direction of force as an object presses against the pad.
Contact pad
The black ribbed surface is the part that touches the object.
Assembled fingertip
The view on the right shows the pad seated on the closed housing.

Contact, made visible

Meet the signal
behind the sensation.

Explore a simulated touch response. Dermis is developing sensing for force, shear, slip, grip, temperature, and contact location.

DERMIS CONSOLESIMULATED
ILLUSTRATIVE SENSOR RESPONSE
Force0.00N
Shear0.00N
Grip0.00N
FORCE OVER TIME (N)Force Shear Grip
35%

Adjust the slider to see example force, shear, and grip readings.

Built around your work

Wherever robots
make contact.

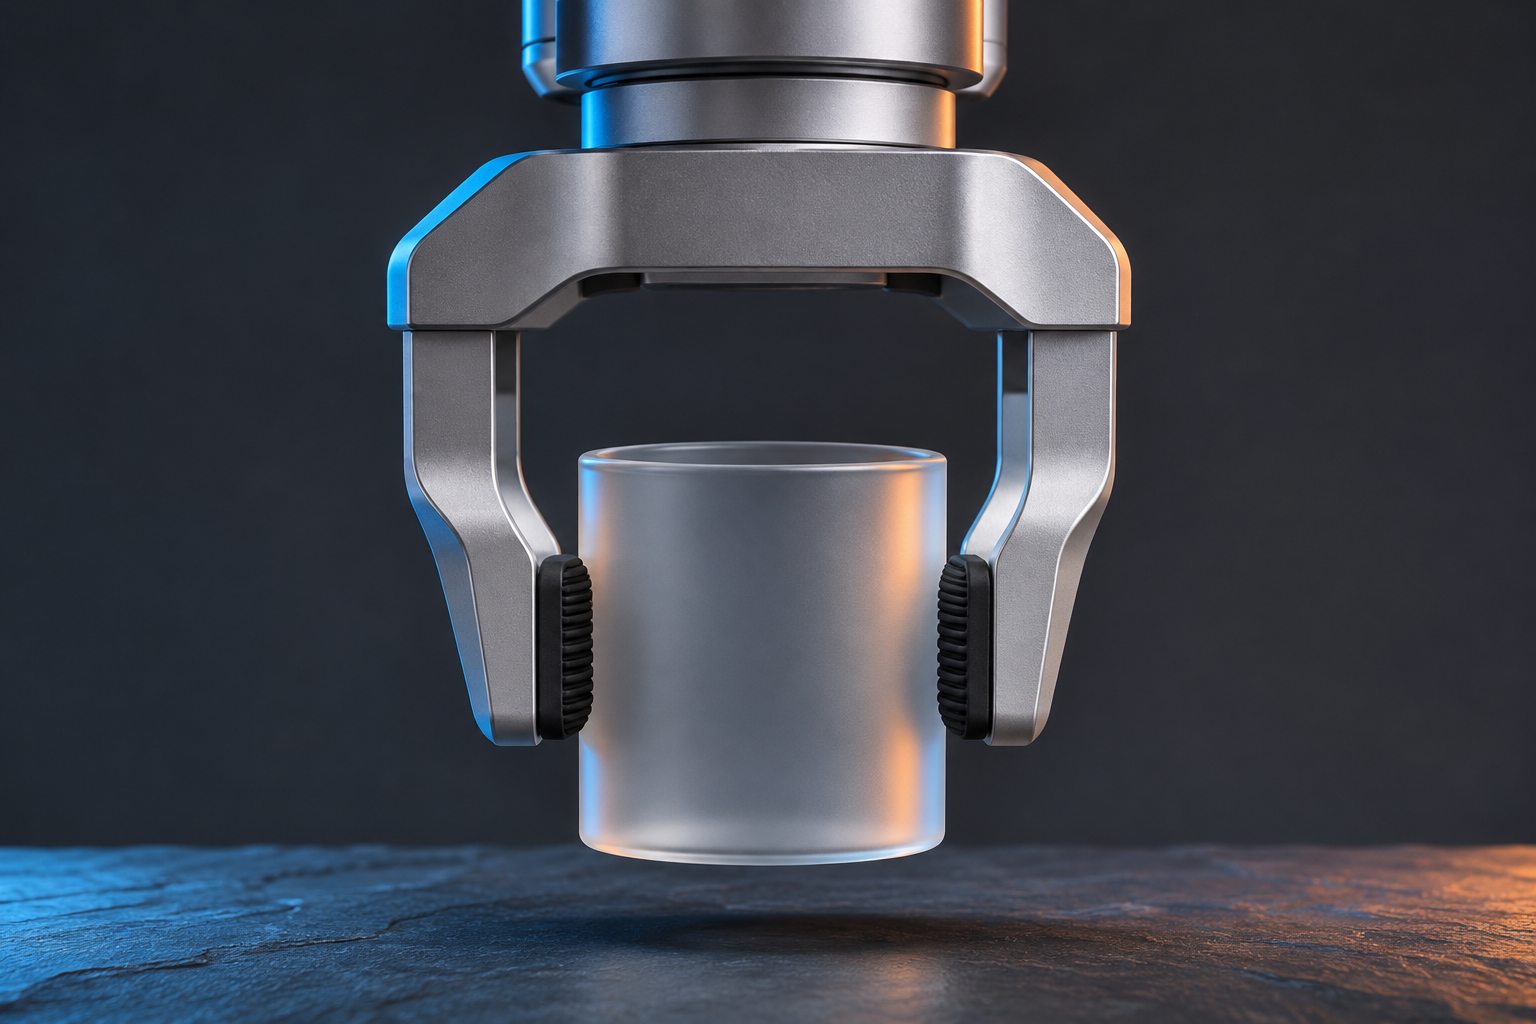
Assembled robotic gripper lifting a frosted glass cylinder with ribbed contact pads

Grippers & manipulation

Contact feedback for parallel grippers handling real, imperfect objects.
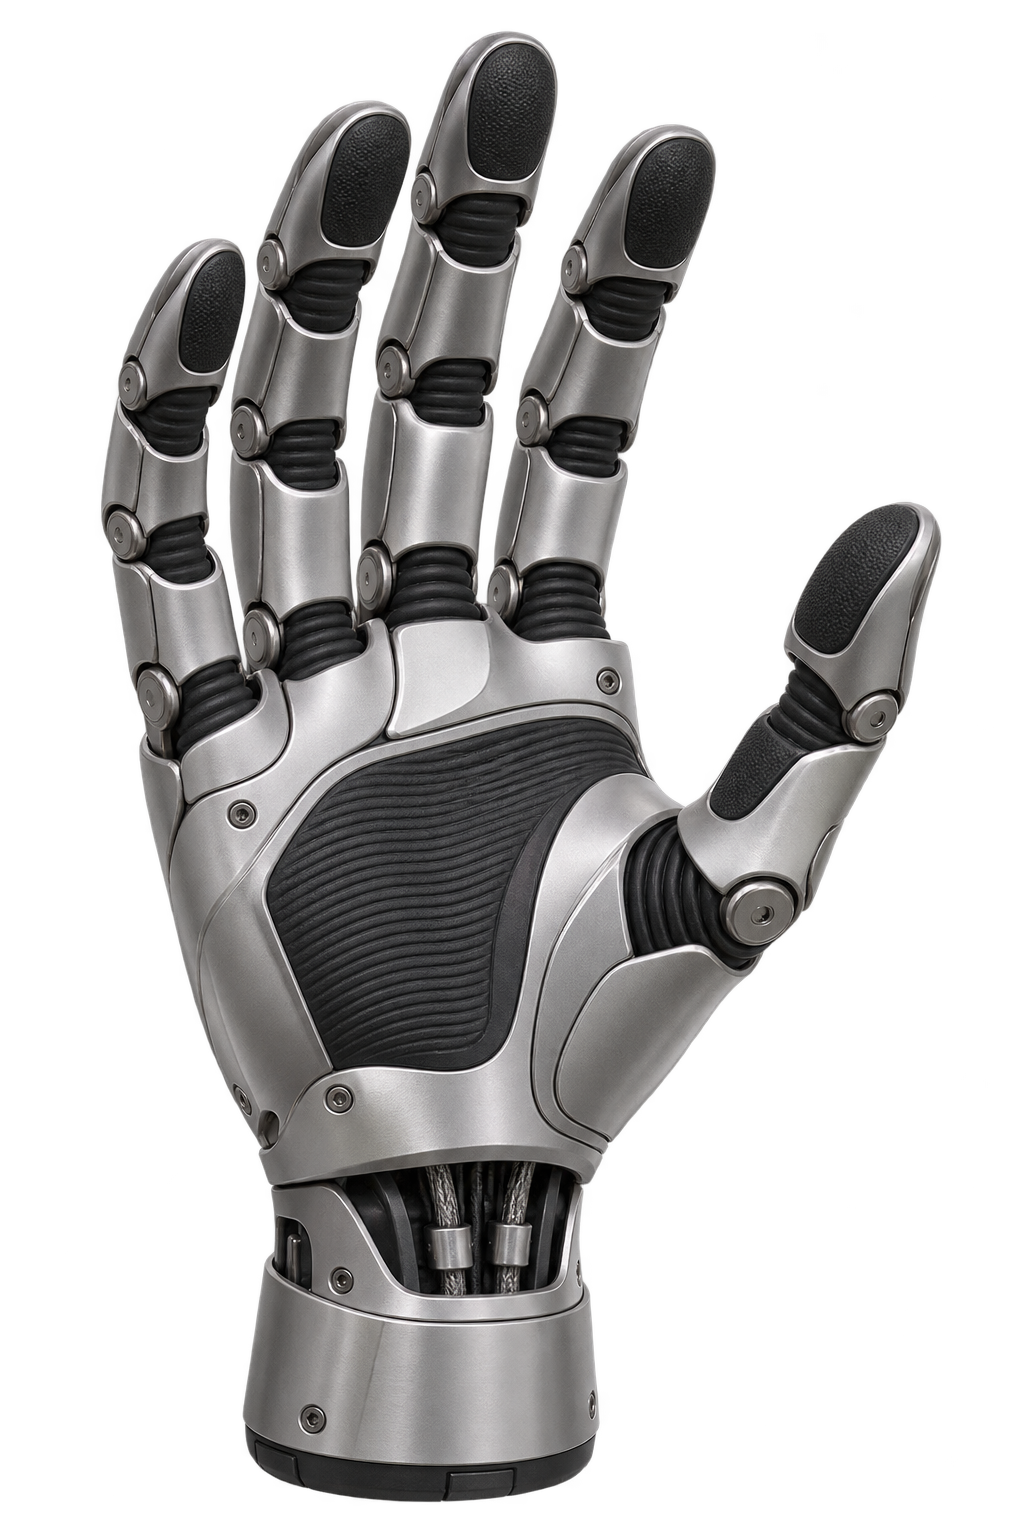
Robotic hand with Dermis skin on fingers and palm

Dexterous hands

Skins for fingertips and palms, so multi-finger hands know what they’re holding.

Conceptual tactile contact surface on a robotic fingertip

Research & robot learning

Use touch to study how robots handle objects and learn new manipulation tasks.

Let’s build what’s next

Give your robot
a sense of touch.

Tell us about your finger, gripper or hand. We’ll explore a tactile skin for its contact surfaces.

hello@dermistouch.com

Delivered via FormSubmit.

DERMIS / PRIVACY

Your project.
Your information.

This website has no analytics or advertising trackers. Interactive product and signal demonstrations run in your browser and do not connect to your hardware.

If you submit the contact form, your name, organization, email, selected interest and message are sent to FormSubmit for delivery to hello@dermistouch.com. Do not include confidential technical information in the form.

You can also contact us directly at hello@dermistouch.com to ask about your inquiry or request deletion of information you have shared.